Amap Releases Humanoid Robot Model λ0 Trained on 500 Hours of Human Video Data
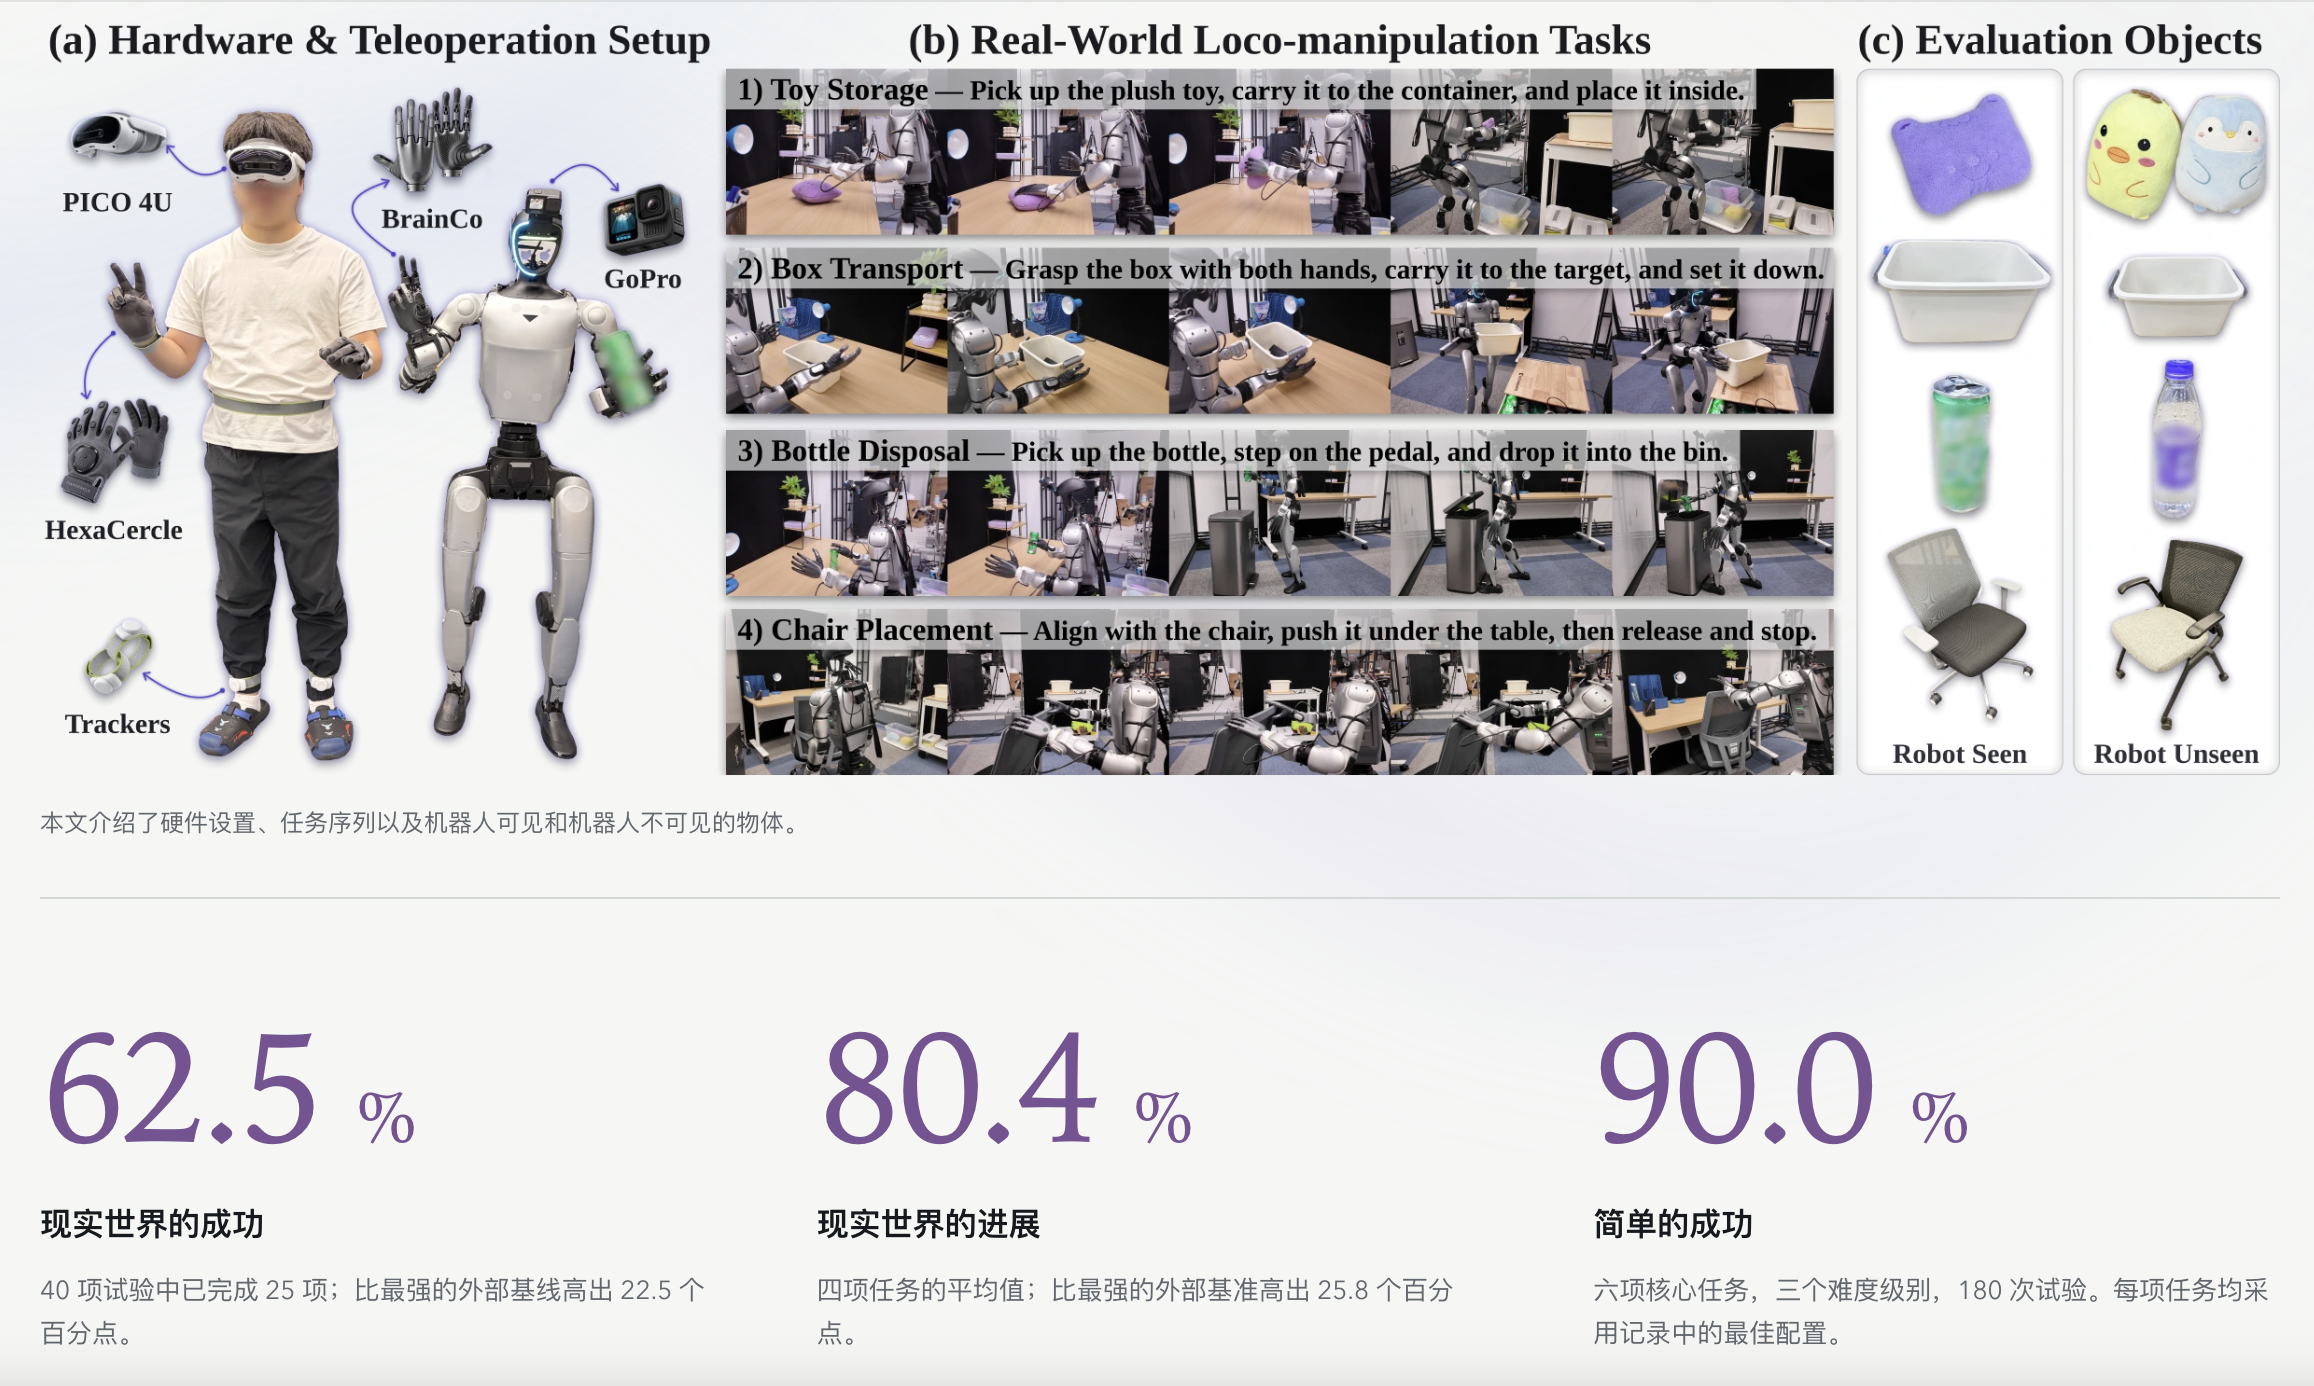
On October 26, Amap and Alibaba's Token Hub business unit jointly released λ0, an embodied AI model trained on videos and motion data of everyday human activity to teach humanoid robots whole-body tasks like walking, carrying and two-handed manipulation. The team built the HumanVerse dataset, 500 hours of human activity captured in open environments — first-person video recorded via wearables, with body motion data, reconstructed hand movements, viewpoint matching and motion alignment converted into humanoid-compatible training data. Training runs in three stages: learning object interaction and hand movements from diverse first-person video, coordinating body and hands on HumanVerse, then adapting to robot tasks. Applied to Unitree's G1 humanoid, λ0 reached a 90.0% success rate on the SIMPLE benchmark and completed 40 runs across four real-world mobile manipulation tasks.
10月26日,高德与阿里巴巴Token Hub事业群联合推出具身智能模型λ₀,尝试利用人类日常活动视频及动作数据训练人形机器人,使其学习行走、搬运和双手操作等需要全身协调的任务。
据项目团队介绍,研究构建了HumanVerse数据集,包含500小时开放环境下采集的人类活动数据。数据通过可穿戴设备记录第一视角视频,并同步采集身体运动信息、重建手部动作,再经过视角匹配和动作对齐,转化为适配人形机器人的训练数据。
训练方面,λ₀采用三阶段训练流程,先通过多样化的第一视角人类视频学习物体交互与手部动作,再利用HumanVerse数据训练身体与手部的协调控制,最后通过针对机器人任务的数据进行适配,团队将相关方法应用于宇树G1人形机器人,探索人类动作经验向机器人控制能力的迁移。
根据项目官网公布的实验结果,λ₀在SIMPLE基准测试中的成功率达到90.0%;在四项真实场景移动操作任务中,模型完成40次测试中的25次,成功率为62.5%,较论文所比较的最强基线高22.5个百分点。
目前,机器人训练仍面临高质量示范数据采集成本高、任务和场景覆盖有限等问题。λ₀尝试将无需机器人参与采集的人类全身动作数据引入训练流程,为扩大具身智能训练数据规模提供了新思路。
上一篇: Even Realities推出G2棕色款智能眼镜,单副经20小时手工打磨
下一篇: 纽约市警察局引入VR模拟训练,覆盖枪击事件、危机干预等复杂执法场景
(*收到爆料后VR陀螺将尽快联系爆料者进行二次确认,并判断内容是否适合发布。)
友情链接: 第十届金陀螺奖 陀螺科技会员 前方智能 游戏陀螺 歌尔 高通 vive PICO 雷鸟创新 亚洲电玩通